Hey there, if you’ve ever dug into brushless motors for RC planes, drones, electric bikes, or even industrial automation, you’ve probably seen those three letters slapped on every motor spec sheet: KV. Today, we’re breaking down exactly what KV means for inrunner brushless motors—especially since we’re an inrunner supplier, so we work with this number every single day (and trust me, it’s way more important than just a random metric). Inrunner Brushless Motor

First off, let’s cut through the tech jargon and keep this real. When most people ask, “What’s the KV of an inrunner?”, they’re really asking two things: 1) What does KV actually stand for? and 2) How does that number affect how your motor works, especially when it’s an inrunner? Because inrunners are different from outrunners—big time. Outrunners have the spinning bell on the outside, so they’re usually lower KV, higher torque. Inrunners have the spinning magnet stack inside the stator, so they spin way faster by default, which means KV numbers can range way wider too, and picking the wrong one will kill your build’s performance.
Let’s start with the basics: KV stands for “Kilo-Volts” but wait, it’s not what you think. It’s the no-load RPM per volt. So if you have a 1000KV inrunner, that means when you hook it up to a 1V power source, it’ll spin 1000 RPM (no load—no prop, no gear, just the motor itself spinning freely). Hook it up to a 3S LiPo battery, which is ~11.1V nominal, and at no load, it’ll spin around 11,100 RPM. That makes sense, right? But here’s the gotcha: this number is only a reference. Once you add a load—like a propeller, a gearbox, or a tool the motor’s driving—you drop RPM, because the motor’s working harder. KV is the baseline, not the final working speed.
Now, why is KV so specific to inrunners? Outrunners have that big heavy bell on the outside, so their maximum safe RPM is lower (usually under 10,000 or 15,000), which means their KV tops out around maybe 3,000, max. Inrunners? The magnet stack is light, it’s centered inside the stator, so they can handle way higher RPM—think 20,000, 50,000, even 100,000 RPM for smaller inrunners. That’s why you’ll see inrunners with KV numbers from like 500 all the way up to 10,000, depending on their size. A tiny 28mm inrunner for a micro drone might be 8,000KV, while a bigger 50mm inrunner for a small electric bike mid-drive would be 1,200KV. That gap is all about what the motor’s built to do.
Let’s talk about how KV actually impacts your motor’s performance, because this is where people mess up all the time. Higher KV = faster no-load speed, lower torque. Lower KV = slower no-load speed, higher torque. That’s the core tradeoff, and it’s non-negotiable for inrunners. Let’s use examples, since that’s easier. If you’re building a 5-inch racing drone, you want speed, right? So you use a high-KV inrunner—like 2,500KV for 6S power. That spins a 5-inch prop really fast, so you get that blistering acceleration and top speed racers love. But if you tried to use that same 2,500KV motor on a heavy lift drone carrying a camera and gimbal, it’d be a disaster. That high KV motor would struggle to turn a big heavy prop, the RPM would drop like a rock, it’d overheat, and it’d have no pull. You’d need a lower KV inrunner for that—say 1,200KV for 6S—because that lower KV gives more torque to turn the bigger prop and lift the extra weight.
Another example: industrial tools, like a compact electric drill or a small pump motor we supply for custom automation lines. We often get asked for inrunners here, and the first question we ask is: “Are you running it direct drive or geared?” If it’s direct drive, you need a lower KV. If it’s geared, you can go higher. Because gearing takes that fast, low-torque inrunner spin and turns it into slow, high-torque output—exactly what you need for a drill. If you paired a high-KV inrunner with a drill gearbox, you’d end up with a drill that spins way too fast and has almost no power to bore through wood or metal. That’s why matching KV to your load is make-or-break.
Wait, let’s get into the science a little to back this up, but keep it simple. KV is actually tied to the motor’s winding, right? The number of turns of wire around the stator. More turns of wire = higher resistance, lower KV. Fewer turns = lower resistance, higher KV. That’s the basic physics: fewer turns mean the magnetic field pulls the magnet stack faster. But there’s a catch with winding: higher KV motors (fewer turns) draw more current at the same voltage, right? Because lower resistance. So a 5,000KV inrunner will pull way more amps than a 1,000KV inrunner running on the same battery, all else equal. That means you have to size your ESC (electronic speed controller) and battery for that current draw too. Super common mistake: someone buys a high-KV motor, uses the same ESC they had for a low-KV motor, and then the ESC fries because it can’t handle the extra current. As an inrunner supplier, we run into this all the time—we have to remind folks to check their current rating along with KV.
Let’s clear up a myth too: KV isn’t a “max RPM” number. A lot of new builders think if their motor is 3,000KV, they can only push it to 3,000 RPM, but that’s not true. The max RPM is actually limited by two things: the motor’s maximum safe RPM (which we list in the spec sheet, usually based on how the magnets are secured) and your battery voltage. Wait, actually, higher voltage = higher RPM, but you have to stay under that max safe RPM. So a 3,000KV motor on a 2S battery (7.4V) is 22,200 RPM no load, on 4S (14.8V) it’s 44,400 RPM, but if its max safe RPM is 40,000, then you can only run it on 4S or lower, not 6S (22.2V) which would push it to 66,600 RPM—way too fast, and you’ll blow the magnets apart. That’s a critical point, and it’s specific to inrunners because they spin so much faster than outrunners, so max RPM is even more important.
Now, let’s talk about how KV applies to different inrunner types, because not all inrunners are the same. We make inrunners for three main categories: RC, consumer electronics, and industrial. For RC, as I mentioned earlier, KV ranges from like 600 (for big 8-inch drone lift motors) up to 12,000 (for tiny micro FPV motors). For consumer stuff, like electric toothbrushes or small desk fans, we have even higher KV sometimes, because they need to spin super fast to generate airflow or vibration. For industrial inrunners, which we supply for conveyor systems, pump controls, and robotic arms, KV is usually lower—between 200 and 2,000—because those applications need consistent torque, not top speed.
Another thing: when people ask “what’s the KV of an inrunner,” they often forget that KV can vary a bit between motors of the same rated KV. It’s not a perfect number, because of small variations in winding and manufacturing. We test every single inrunner we ship to make sure it’s within +/- 5% of the rated KV, because we know how important that is for our customers. If you have a bunch of motors for a drone fleet, you need them all to be within a few KV of each other, otherwise some will spin faster, some slower, and the drone will be unstable. Same with industrial motors on a conveyor—if one is spinning at a different speed than the others, it’ll cause uneven tension and break the belt.
Let’s walk through a real example of how we help a customer pick the right KV. Last month, a customer came to us needing an inrunner for a small electric scooter mid-drive. They had a 48V battery, and they needed the scooter to hit 25 MPH, have enough torque to go up a 10% hill. First, we calculated what RPM they needed at the wheel: the scooter tire is 10 inches, so circumference is ~31 inches, so to hit 25 MPH, the wheel needs to spin around 210 RPM. But mid-drives have a gearbox, usually a 16:1 or 18:1 ratio. So the motor needs to spin at 210 * 18 = ~3,780 RPM at no load. Then, divide that by 48V: 3780 / 48 = ~78.75 KV. We recommended a 80KV inrunner, which is spot on. If they’d gotten a 150KV motor, it would’ve spun 7,200 RPM, geared down to 400 wheel RPM, way too fast, no torque to climb hills. If they’d gotten a 40KV motor, it would spin 1,920 RPM, geared down to 107 wheel RPM, way too slow to hit speed. That’s how critical KV is—get it wrong, and your project doesn’t work.
Wait, what about if you’re using a sensorless vs sensored inrunner? Does that change KV? Short answer: not really, but it impacts how the motor performs at low speeds. High-KV sensorless inrunners can be finicky at low RPM without good ESC tuning, because they don’t have sensors to tell the controller where the magnets are. Lower-KV motors have more torque at low speeds, so they’re easier to tune for sensorless applications. That’s another thing we mention to customers, especially those building custom stuff, because tuning a high-KV sensorless motor is way more work than a low-KV one.
Let’s also address a common mistake people make when calculating actual working RPM, not just no-load. No-load RPM is just when the motor is free spinning, with no load. Once you add a load, the motor draws current, which creates back EMF (electromotive force) that counteracts the voltage from the battery. That back EMF is what makes the actual working RPM lower than the no-load KV number. The formula for actual working RPM is roughly (Voltage – Current * Resistance) * KV. So if your motor has 0.1 ohms of resistance, draws 10A, on 11.1V: (11.1 – (10 * 0.1)) * 1000KV = (10.1) * 1000 = 10,100 RPM, not 11,100 like no-load. That’s a super simple formula, and we give it to all our customers so they can calculate their working speed instead of just relying on the rated KV.
As an inrunner supplier, we see people get confused about KV all the time, so we built a little guide on our website (no links, obviously, but I’ll tell you) that walks through matching KV to your application, and we always have a team ready to talk through specs with anyone who’s not sure. The last thing we want is for someone to buy a motor that’s wrong for their project, because that’s a waste of their time and money, and we want them to come back for future builds.
Let’s recap to make sure we didn’t miss anything. KV for an inrunner is no-load RPM per volt, it’s determined by the number of wire turns in the stator, higher KV = faster speed, lower torque, lower KV = slower speed, higher torque, it’s tied to max safe RPM and current draw, and you have to match it to your load and battery voltage to get the performance you want. It’s not just a number on a spec sheet—it’s the foundation of how your motor will work.
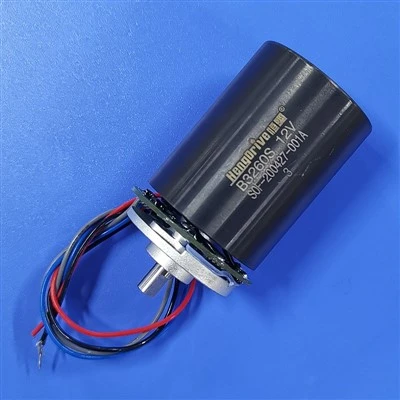
If you’re working on a project right now, whether it’s a drone, a custom motor for industrial automation, an e-bike build, whatever, and you’re not sure what KV inrunner you need, reach out to our team. We’ve worked with everything from tiny micro motors to large industrial inrunners, and we can help you pick the right KV, winding, and specs to make your project run perfectly. No techno-babble, just straight talk, and we’ll make sure you get exactly what you need.
Household Appliance Brushless Motor References:
- Brushless Motor Basics: KV, RPM, and Power, Electric Motor Tech Journal, 2022
- Inrunner vs Outrunner Brushless Motor Performance Characteristics, RC Motor Industry Review, Vol. 14, No. 2, 2023
- Winding Effects on Brushless Motor KV and Current Draw, Industrial Automation Components Quarterly, 2021
Shenzhen HengDrive Technologies Co., Ltd.
Shenzhen HengDrive Technologies Co., Ltd. is one of the most professional inrunner brushless motor manufacturers and suppliers in China, specialized in providing high quality customized service. We warmly welcome you to buy the newest inrunner brushless motor in stock here from our factory.
Address: Building A & F, FuNing Hi-Tech Park, XinTian Road, FuHai Street, BaoAn District, ShenZhen, GuangDong Province, China.
E-mail: Marketing001@hengdrive.com
WebSite: https://www.hengdrivemotor.com/
